Major version · December 2025
V1.0: Scrimmage build
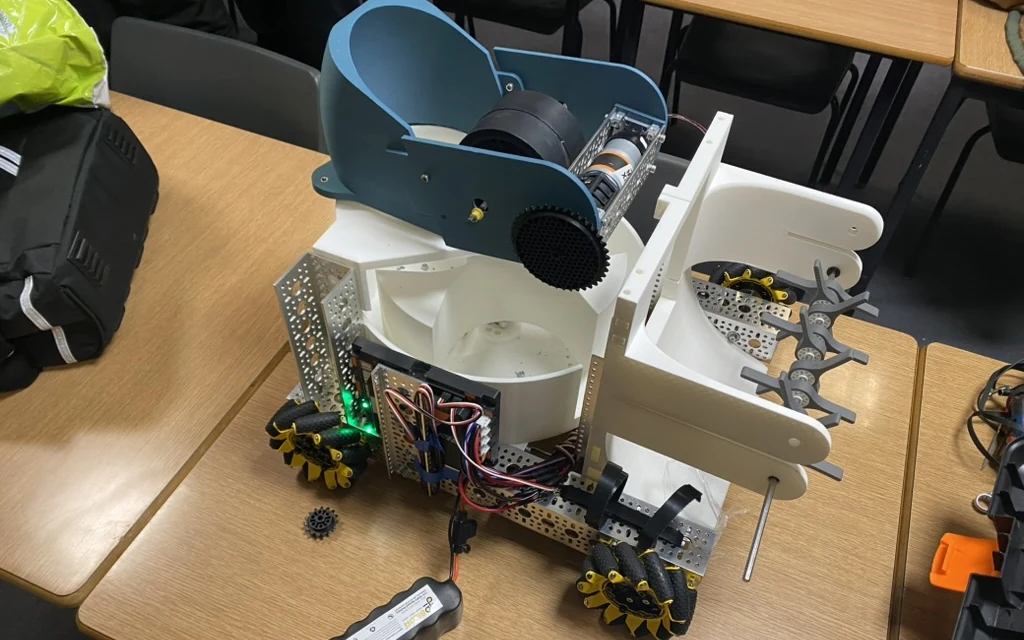
Full assembly
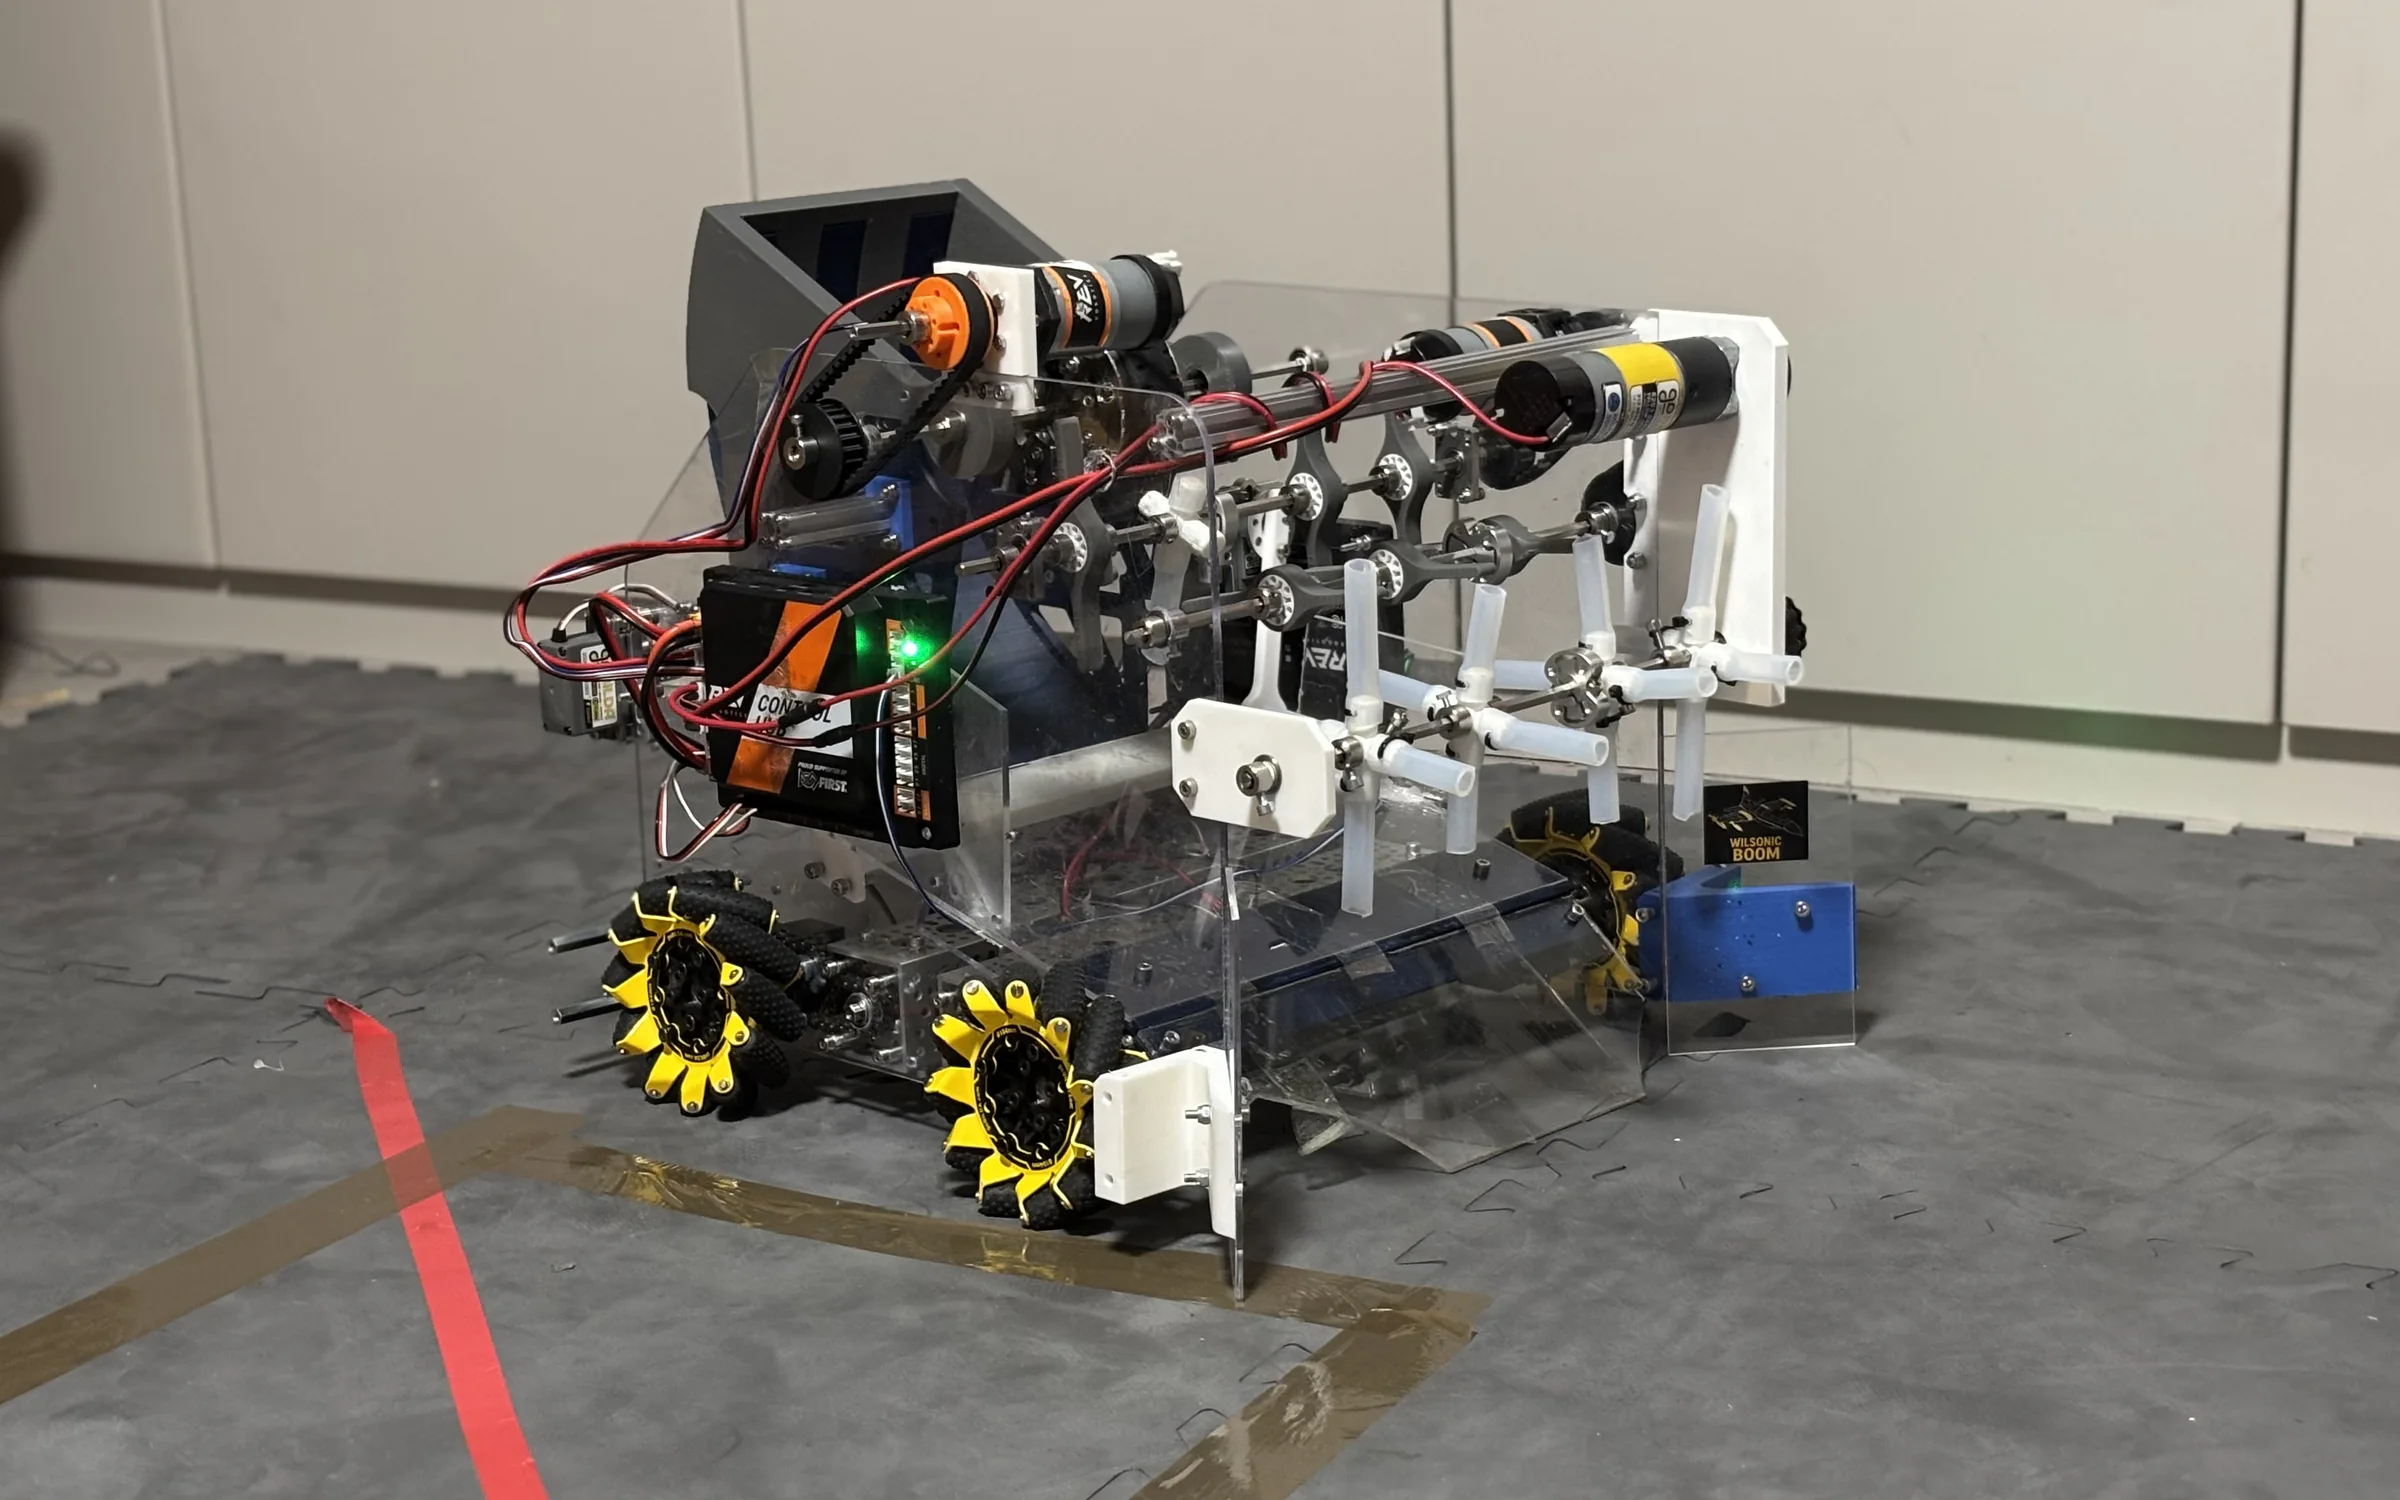
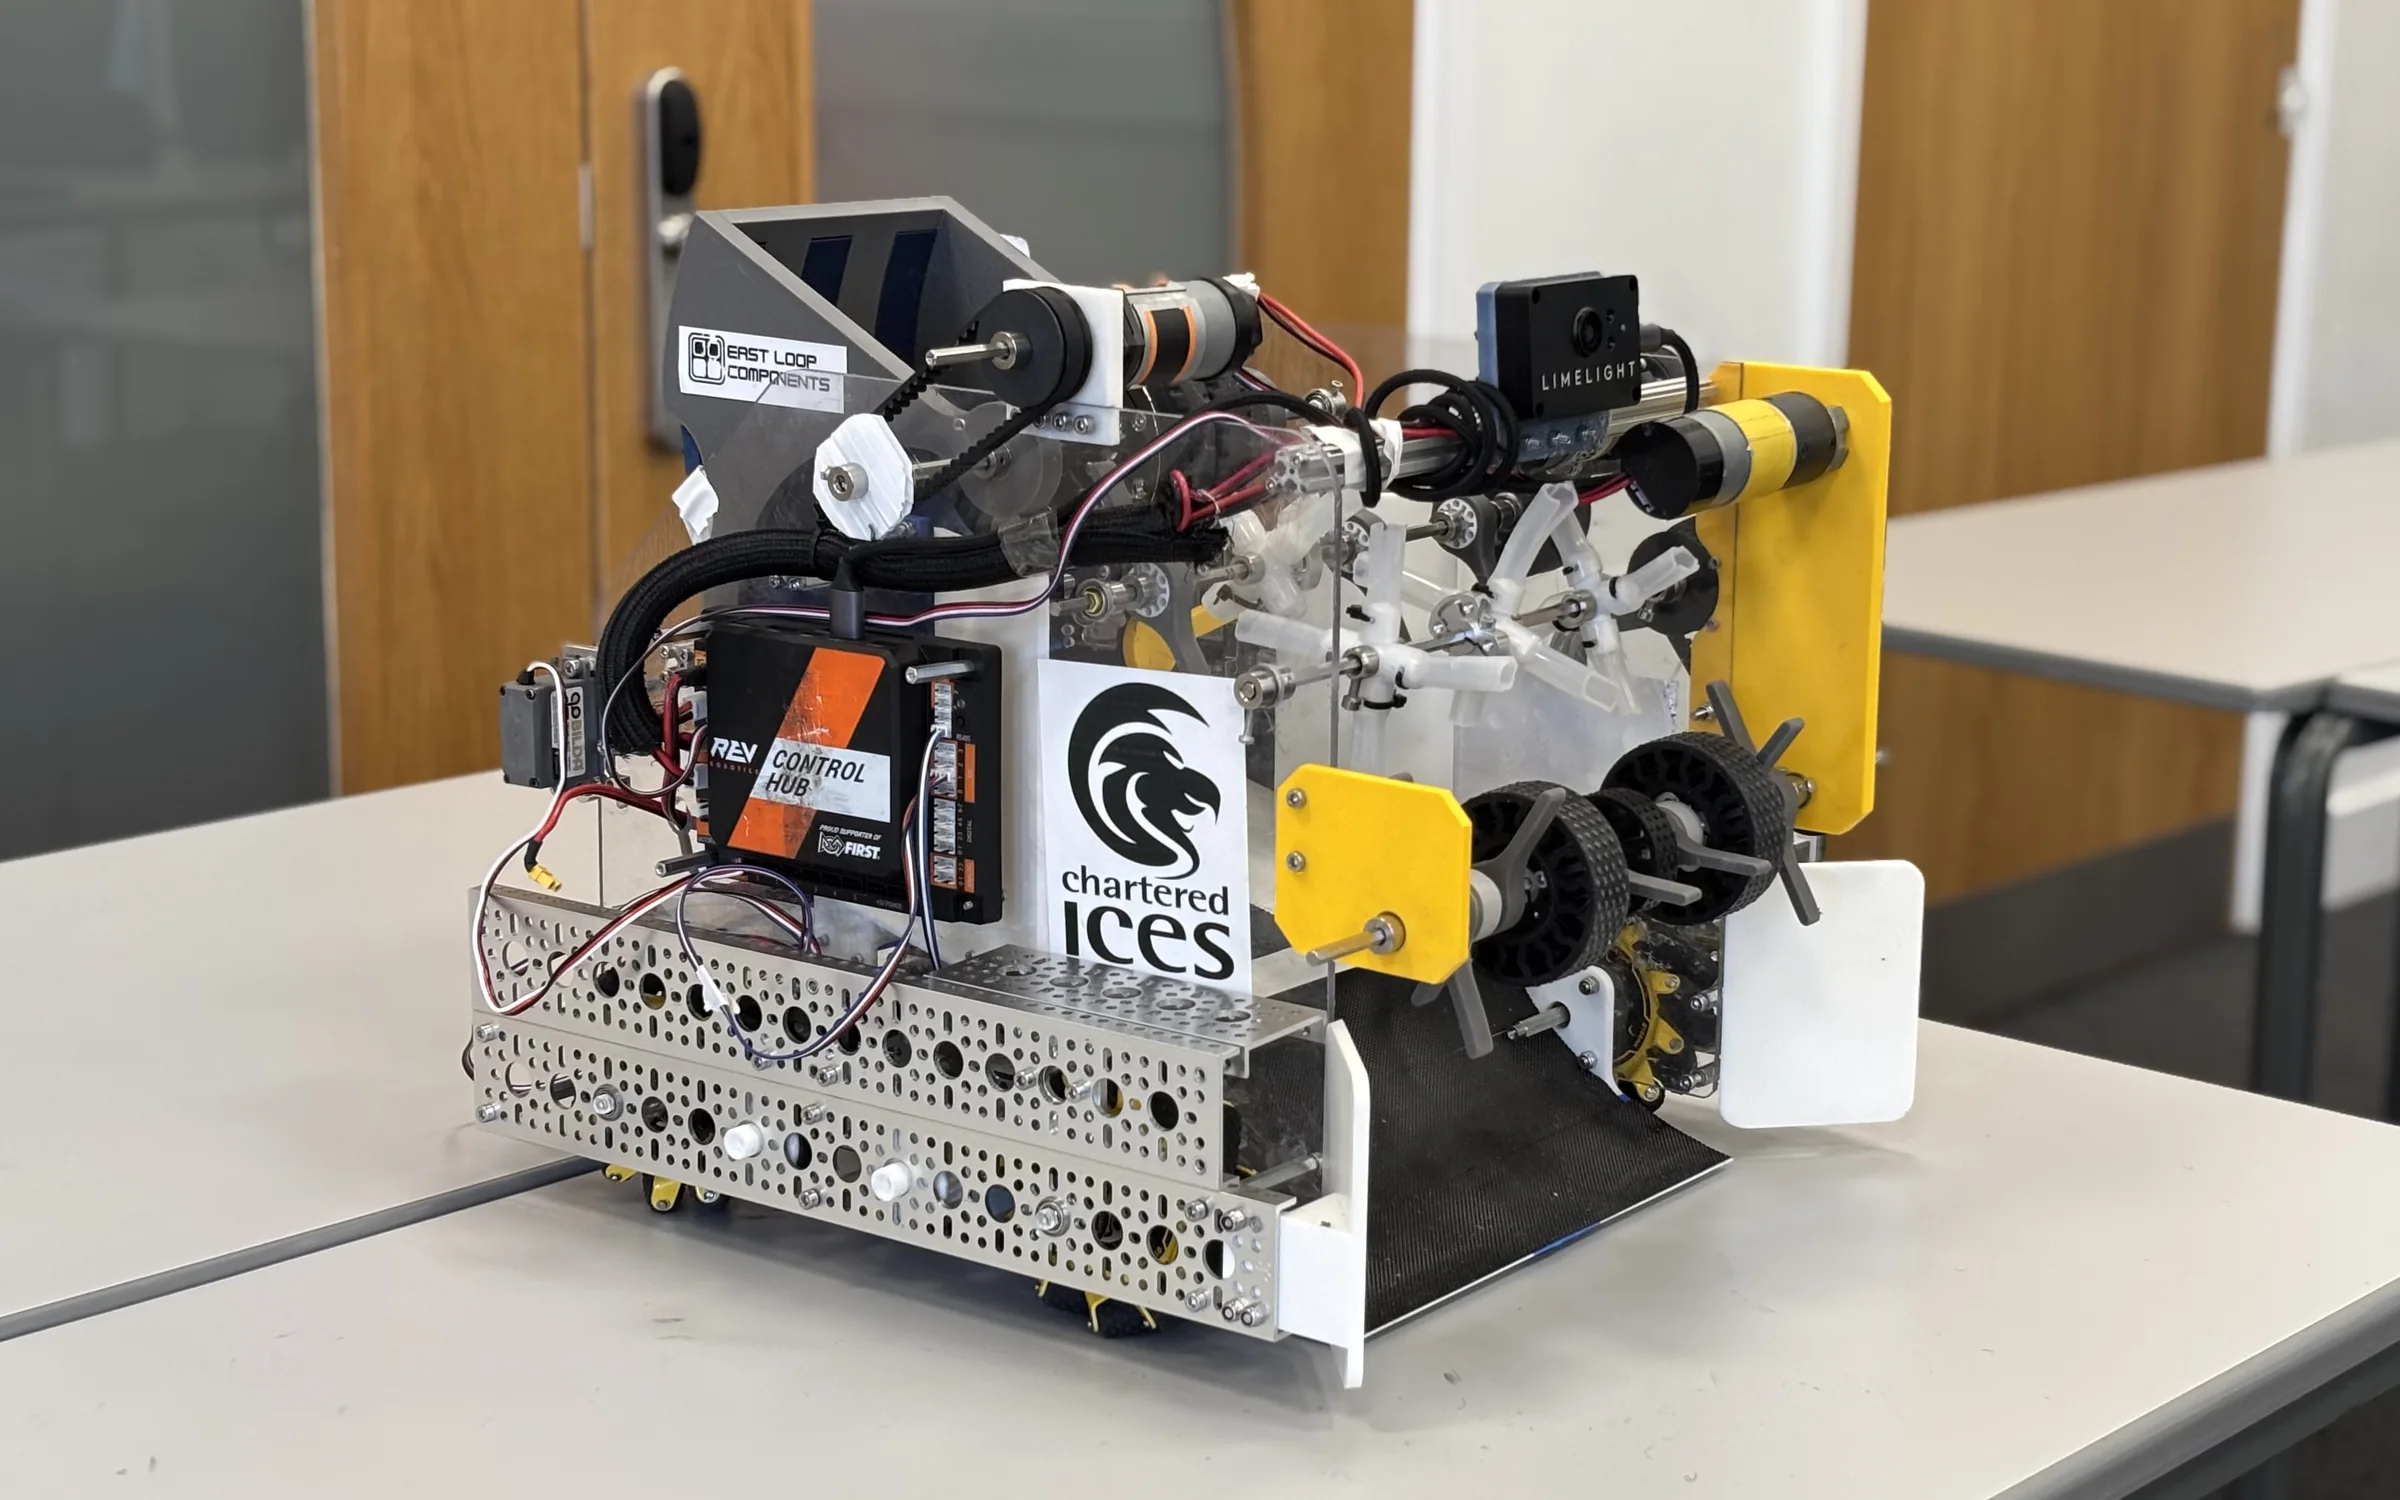
The first robot we built as a team.
- Drivetrain
- A mecanum strafer, chosen because it is simple, reliable and sturdy.
- Intake
- Flap wheels and a curved ramp, to pick artifacts up quickly.
- Sorter
- Sorting turned out not to help our scoring, and the flap that fed the shooter was unreliable, which made our cycles slow.
- Shooter
- It worked, but we had no control over the angle of its hood.
- Motors
- 6
- Servos
- 2
1Drivetrain
A mecanum strafer drivetrain, chosen because it is simple, reliable and sturdy.
Four motors, one per wheel, on a frame of U-channel that keeps it stiff.
- Motors
- 4
- Servos
- 0
2Intake
A flap-wheel intake with a curved ramp, for quick pick-up of artifacts.
One motor drives the flap wheels. The ramp is 3D printed.
- Motors
- 1
- Servos
- 0
3Sorter
A spindexer: a drum that rotates to sort the artifacts by colour.
Two servos turn it. Sorting turned out not to help our scoring, and the flap that pushed each artifact on into the shooter was unreliable, which slowed every cycle.
- Motors
- 0
- Servos
- 2
4Shooter
A hooded flywheel shooter that fires the artifacts into the goals.
One motor spins the flywheel. It worked, but the hood was fixed, so we could not control its angle.
- Motors
- 1
- Servos
- 0